Studying computer science at the University of Waterloo.
Was that life? Well then! Once more!
Find me on GitHub, or reach me at gabriel@nakamoto.ca or gnakamot@uwaterloo.ca.
Self-driving cars at WATonomous
Camera and LiDAR visualizations for autonomous driving.
A drive around ring road with synchronized camera views and point-cloud segmentation, alongside BEVFusion's bird's-eye-view map predictions.
More on this when I have time.
Paper↗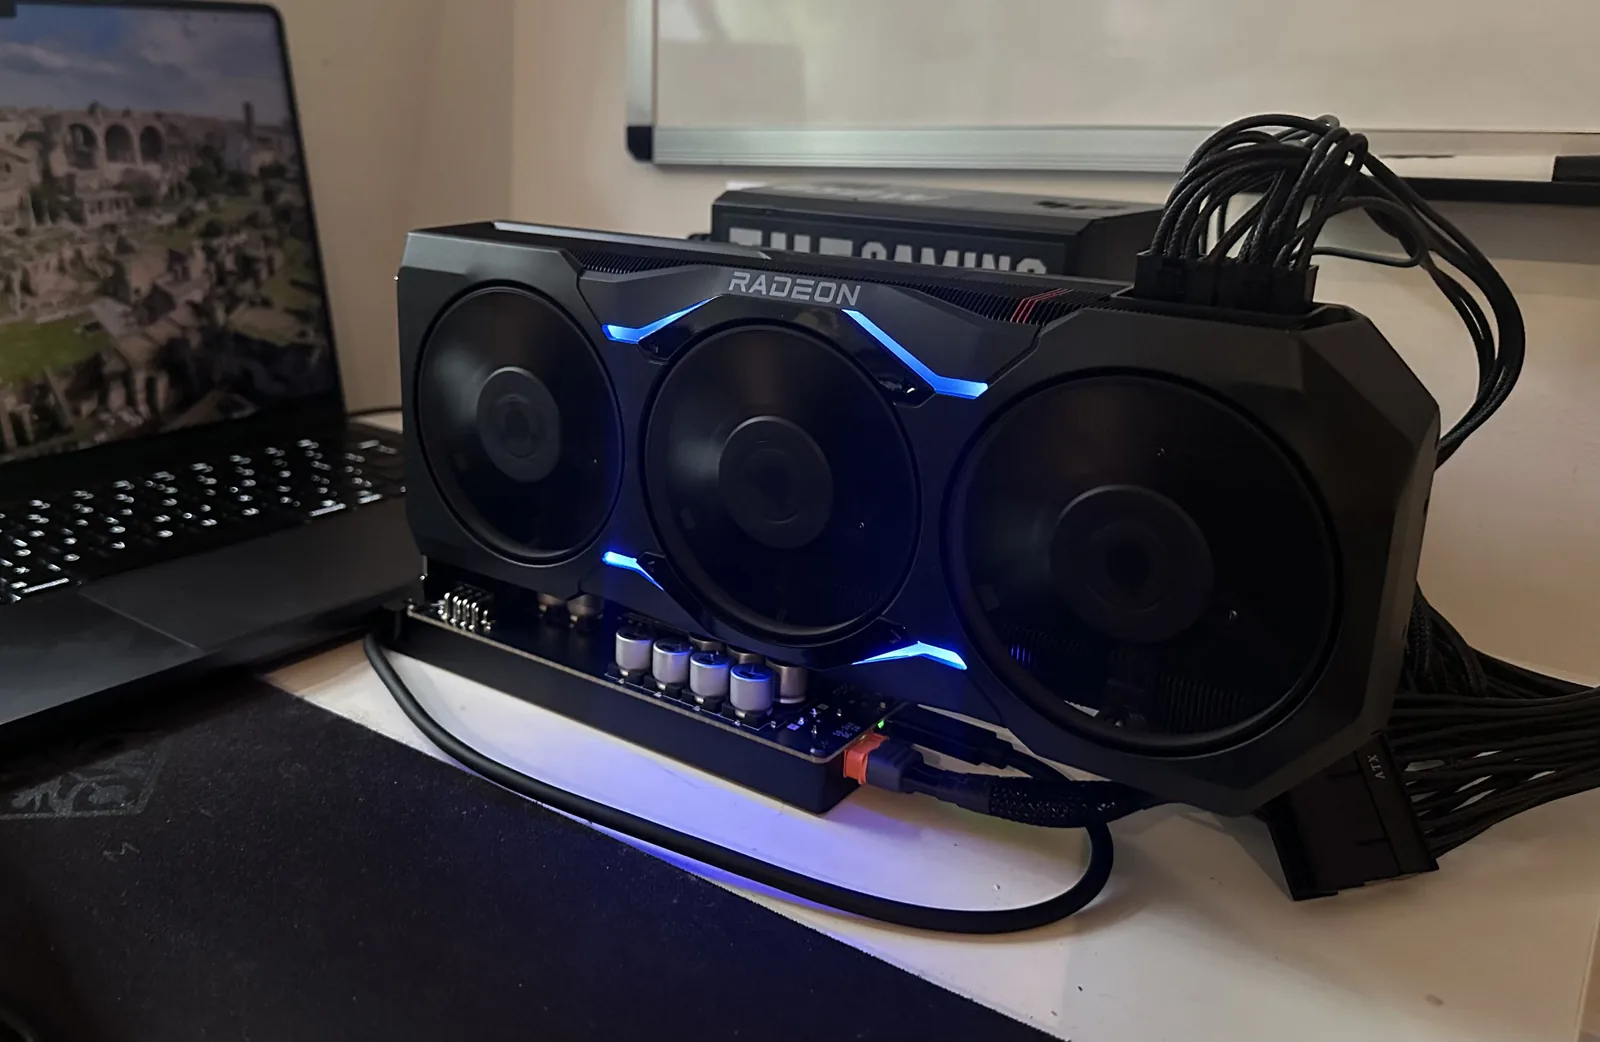
tinygrad / RDNA3
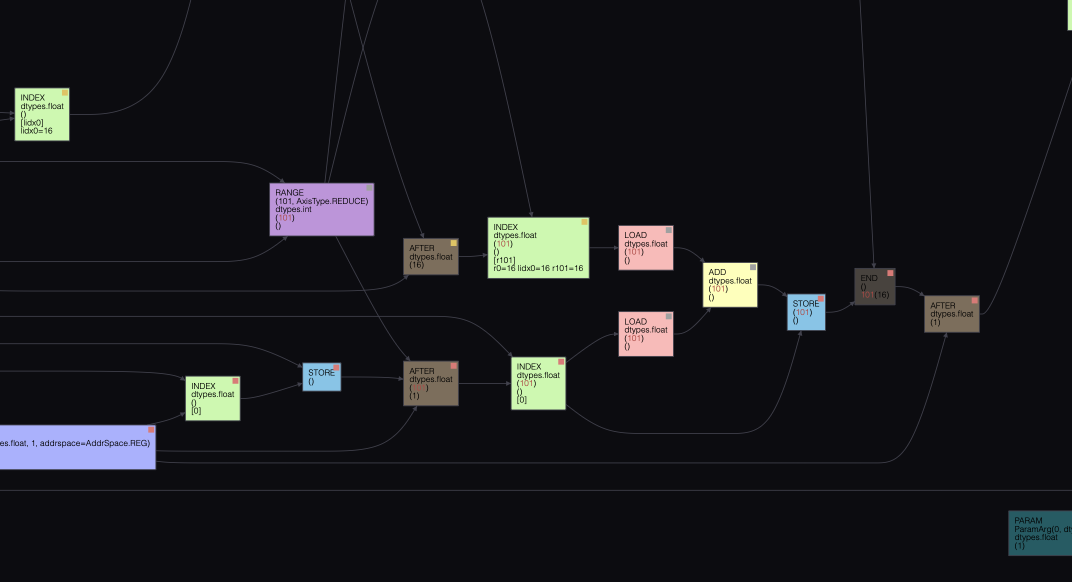
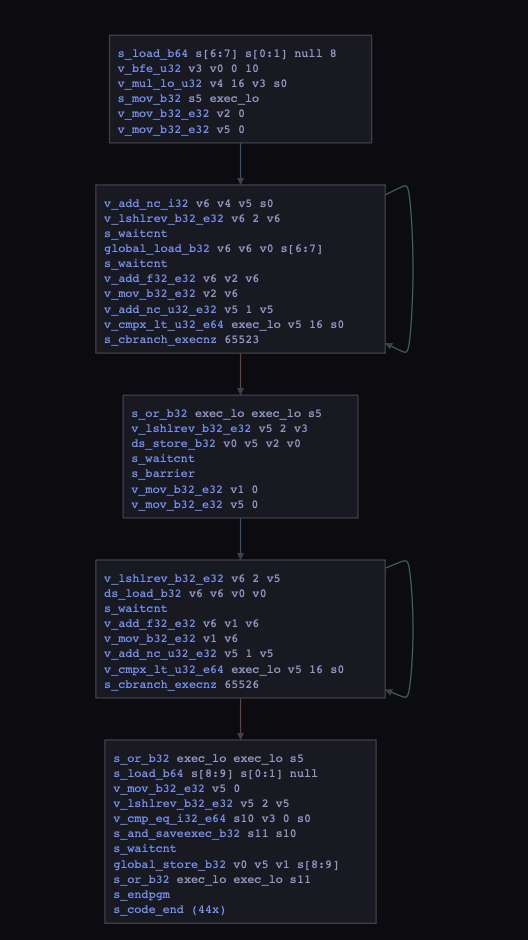
Building an open-source RDNA3 compiler backend for tinygrad.
Instruction selection, register allocation with multi-register constraints and SGPR/VGPR spilling, SSA promotion, control-flow lowering, and architecture-specific analysis.
Integrates with tinygrad's declarative pattern-matching and rewrite framework and universal UOp IR. Supports GPU acceleration features including WMMA.
FRC Robots
Two FRC robots. Bruce competed at the 2025 world championship with a top 1% autonomous routine.
Multi-camera pose estimation fused with drivetrain odometry, shoot-on-the-move turret tracking, and autonomous motion planning with custom control systems.
Offline hardware logging and replay, 2D physics simulation, and mechanism visualization.
Source code ↗